



Open hardware
Thenar Arms
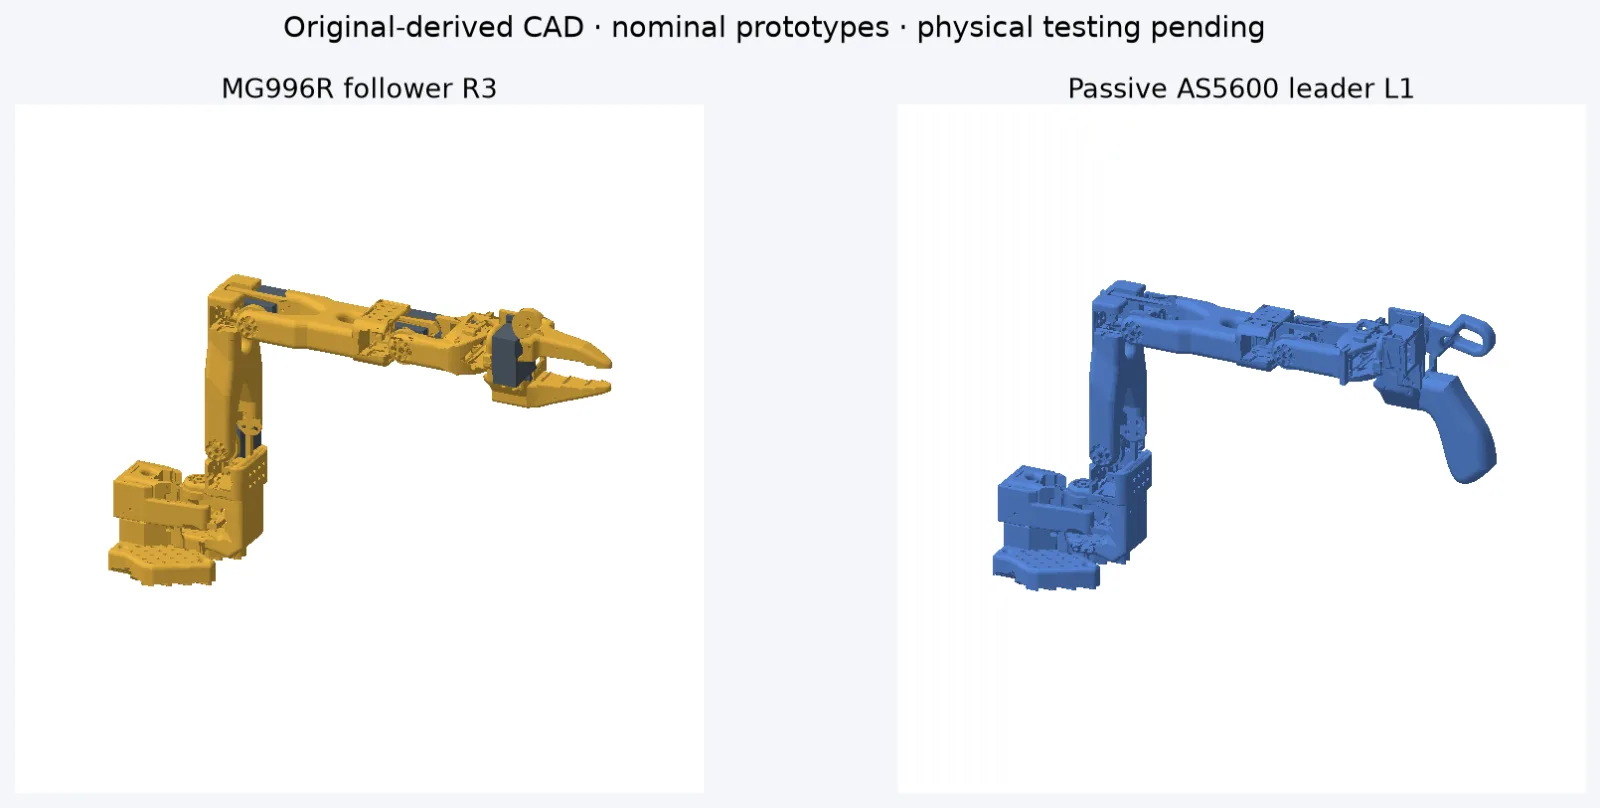
A robot arm pair you can print: a passive leader and an MG996R follower.
github.com/nickthelegend/thenar-arms →Robots you can print, the rigs that drive them, and a market that pays people on Monad for every run they record.
Built with
Robots learn from people.
Physical AI is starved of real demonstrations.
ThenarLabs builds the robots, the rigs that drive them, and the market that pays the people who teach them.
What we build
A robot arm pair you can print: a passive leader and an MG996R follower.
github.com/nickthelegend/thenar-arms →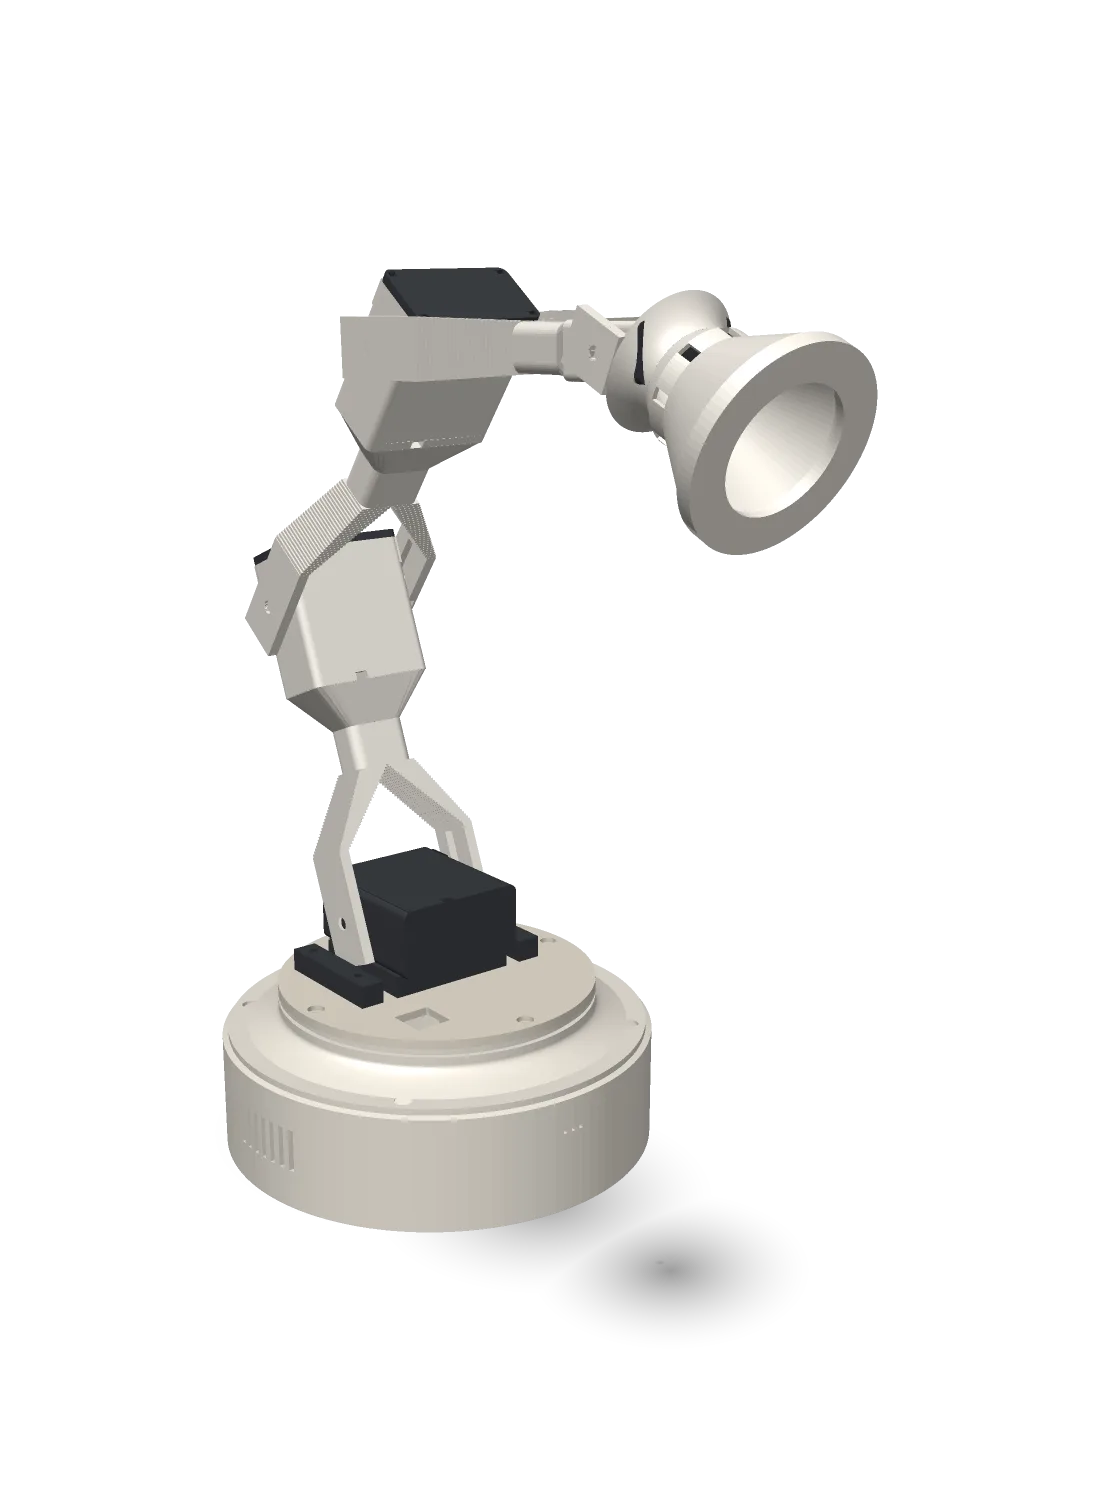
An animated desk lamp that sees, hears and moves.
github.com/nickthelegend/hotaru →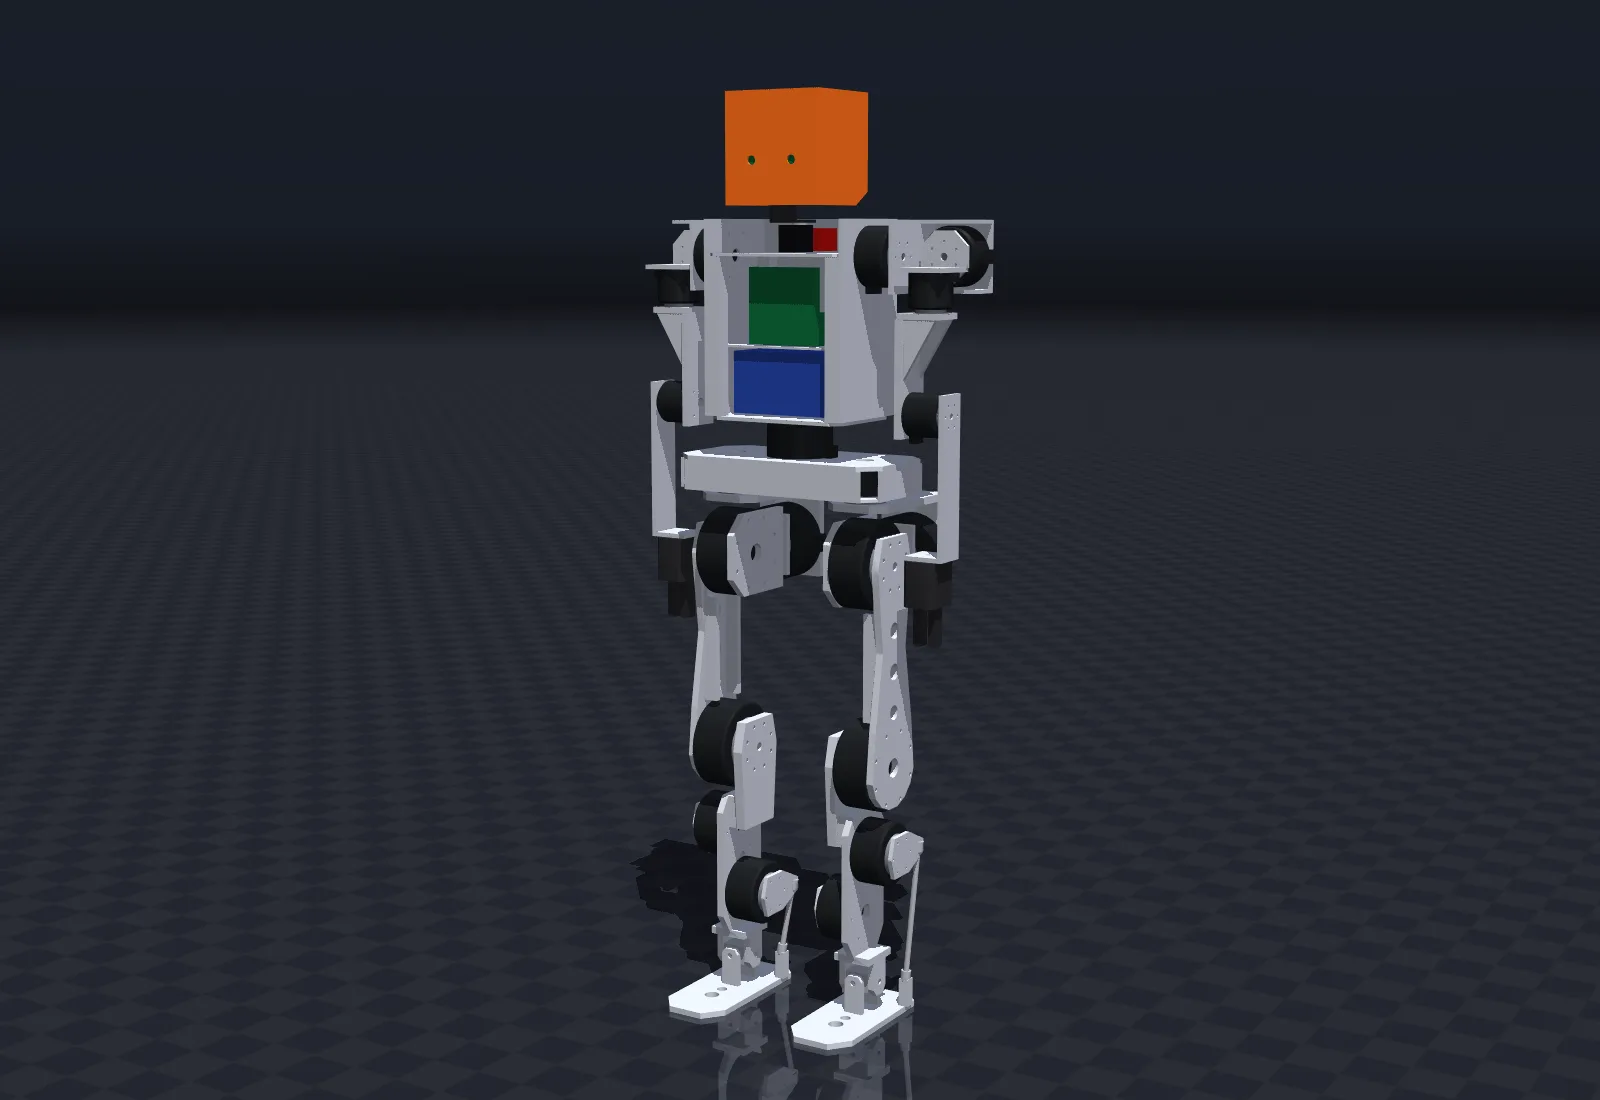
A full-size walking humanoid designed to be built in India.
github.com/nickthelegend/thenar-jx1 →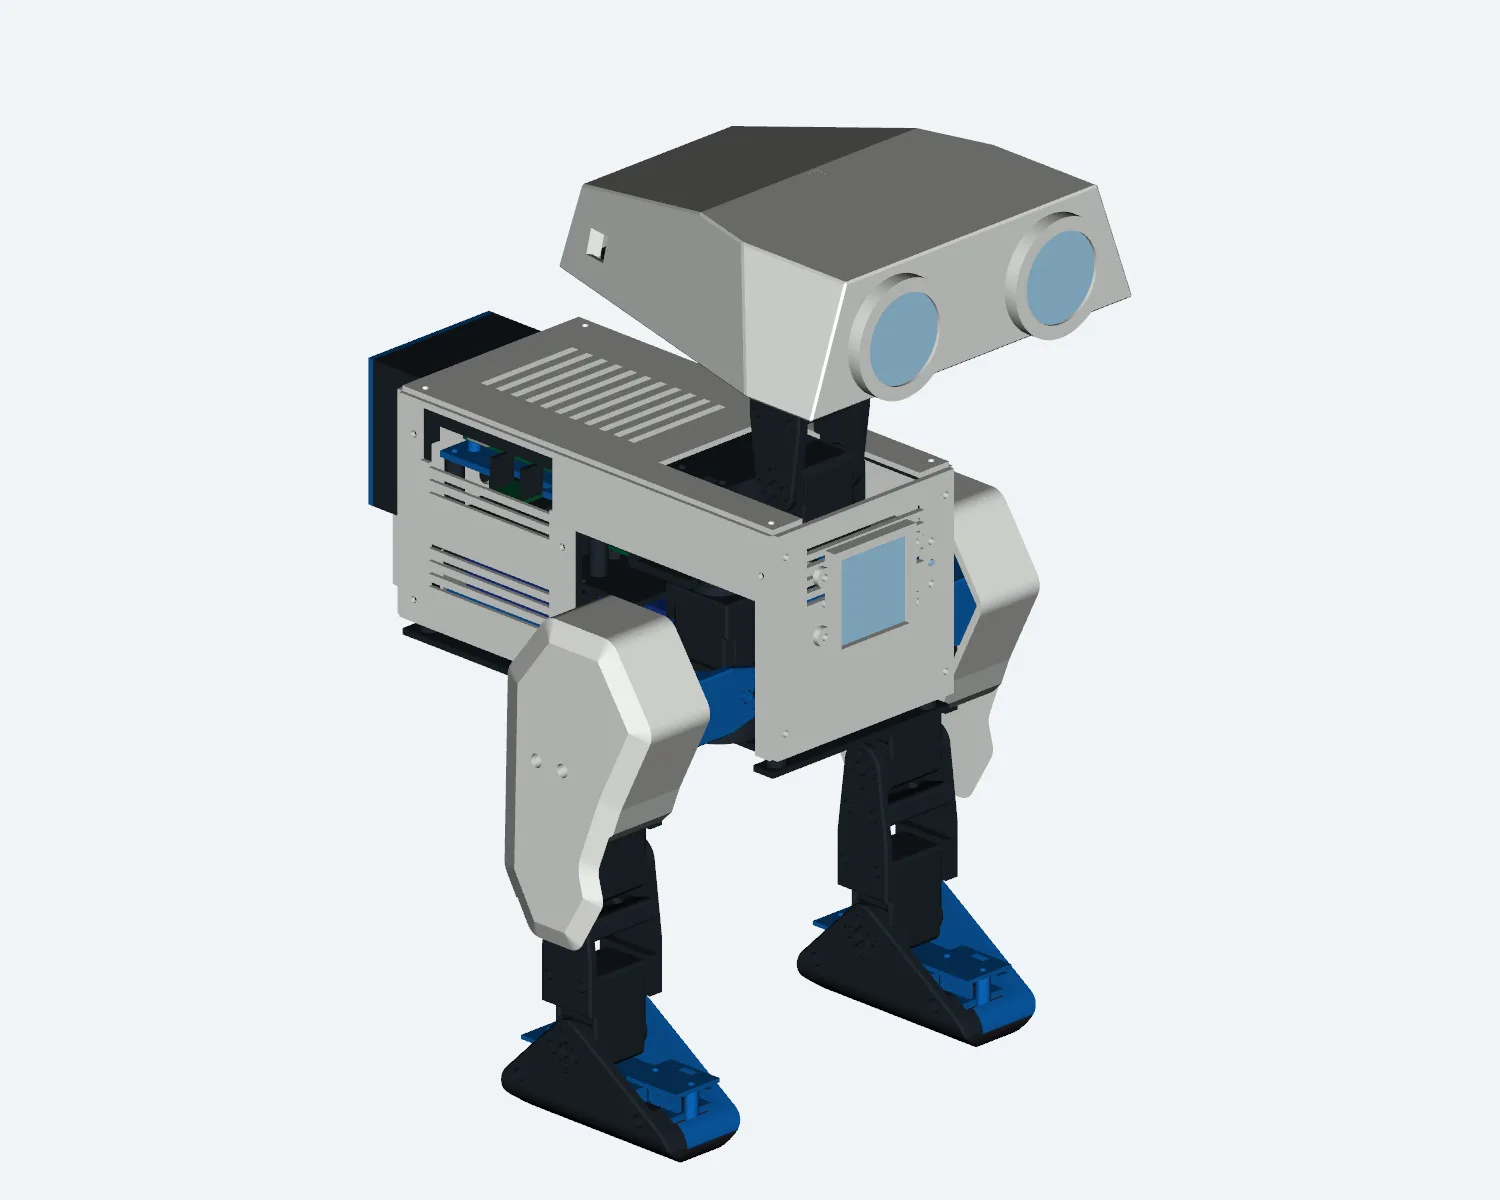
A 14-servo duck robot, printed on a P1S in four colours.
github.com/nickthelegend/thenar-duck →
A printable 240 mm Formula-style simulator wheel, engraved ThenarLabs.
github.com/nickthelegend/racingwheel →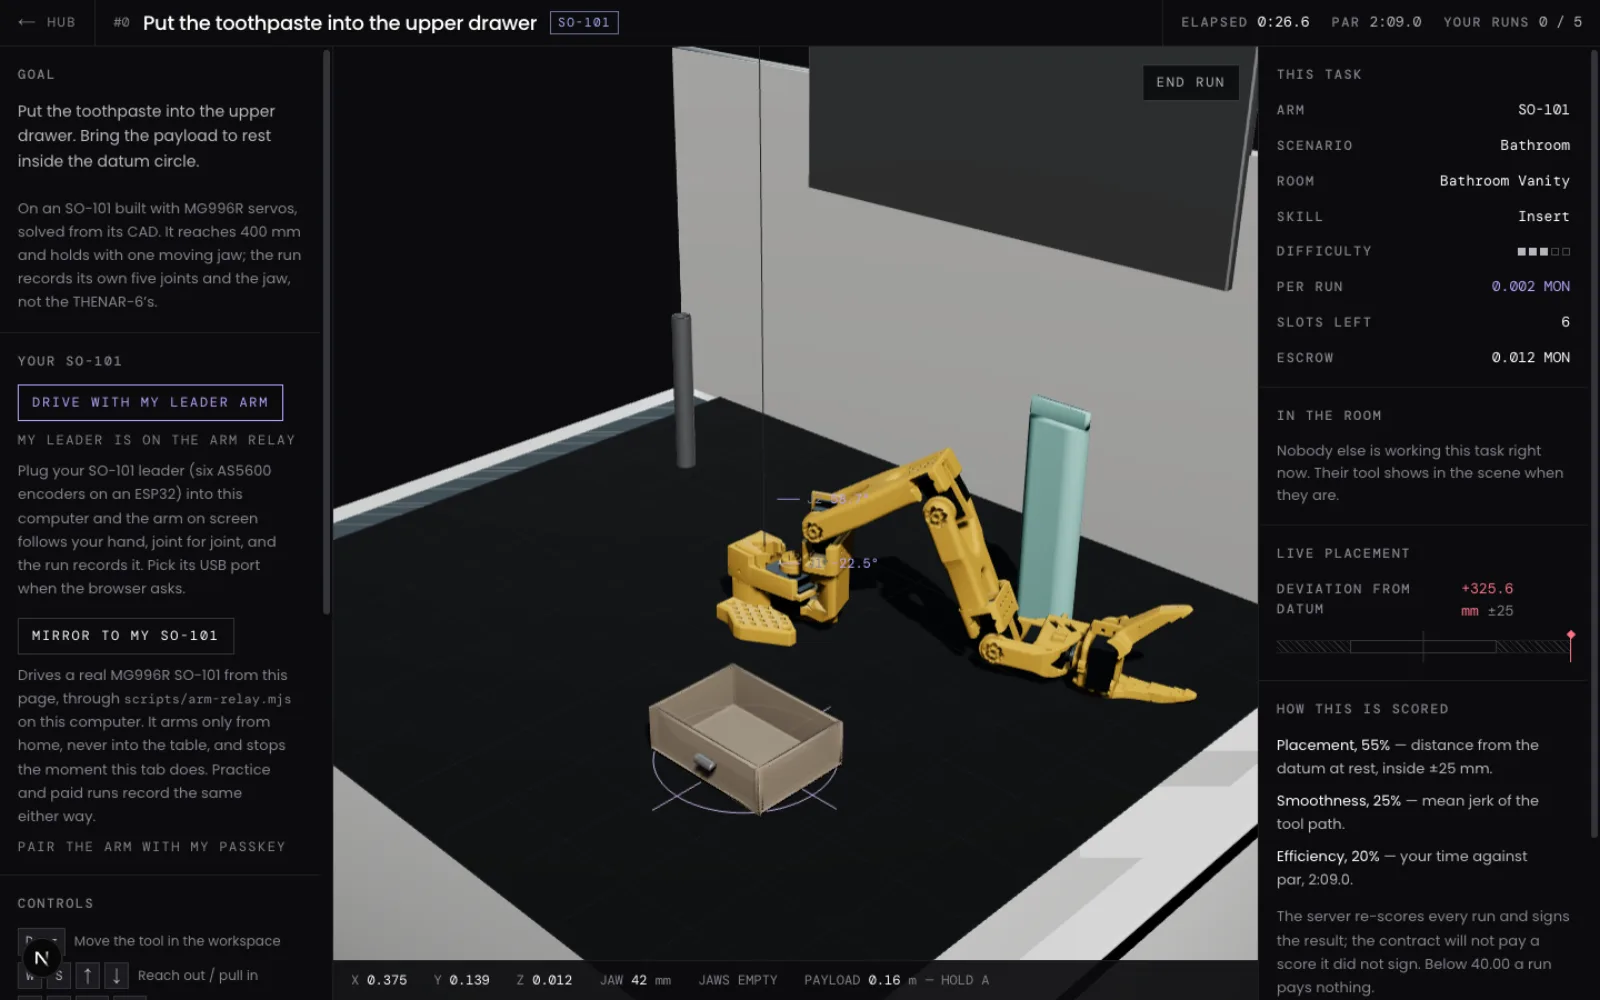
People teach robots, and get paid on Monad for every run they record.
github.com/nickthelegend/thenar-monad →How Thenar works
Take a task and do it with a robot arm: from the browser, a Meta Quest 3S on your own table, or a leader arm in your hand.
A verifier measures the run and signs its score. One Monad transaction records it and pays you, in the block that holds it.
Every paid run issues your share of the corpus. Labs and AI agents buy it per task, and every sale is logged with its hash.
12
funded tasks on Monad Testnet
25
paid runs still open to anyone
0.079 MON
in escrow, paid out per run
A physical AI lab. We design robots anyone can print and build, the teleoperation rigs that drive them, and Thenar, the market where the people who teach robots are paid for it.
No. Every task runs on a simulated arm at true scale in the browser or in a Meta Quest. A physical SO-101 leader or follower is optional: it drives the same recording.
In MON on Monad, by the same transaction that records the run, from escrow the task's funder put up front. The station shows the payout and what it cost to settle.
A paid run needs a person behind the address: a passkey checked on chain through Monad's P-256 precompile. The verifier also rejects a recording whose arm never really carried the object.
Robotics labs and AI agents. An agent asks for a task's corpus over HTTP, pays a cent of USDC through x402, and checks the file against the sale logged on Monad.
Yes. Thenar Arms, JX1, JX0 and the Thenar Duck publish their CAD, print files, parts lists and firmware on GitHub. None of it is payload rated yet, and each repository says what has and has not been proven on a bench.
Pick a funded task, drive the arm, and be paid on Monad before the page finishes telling you so.